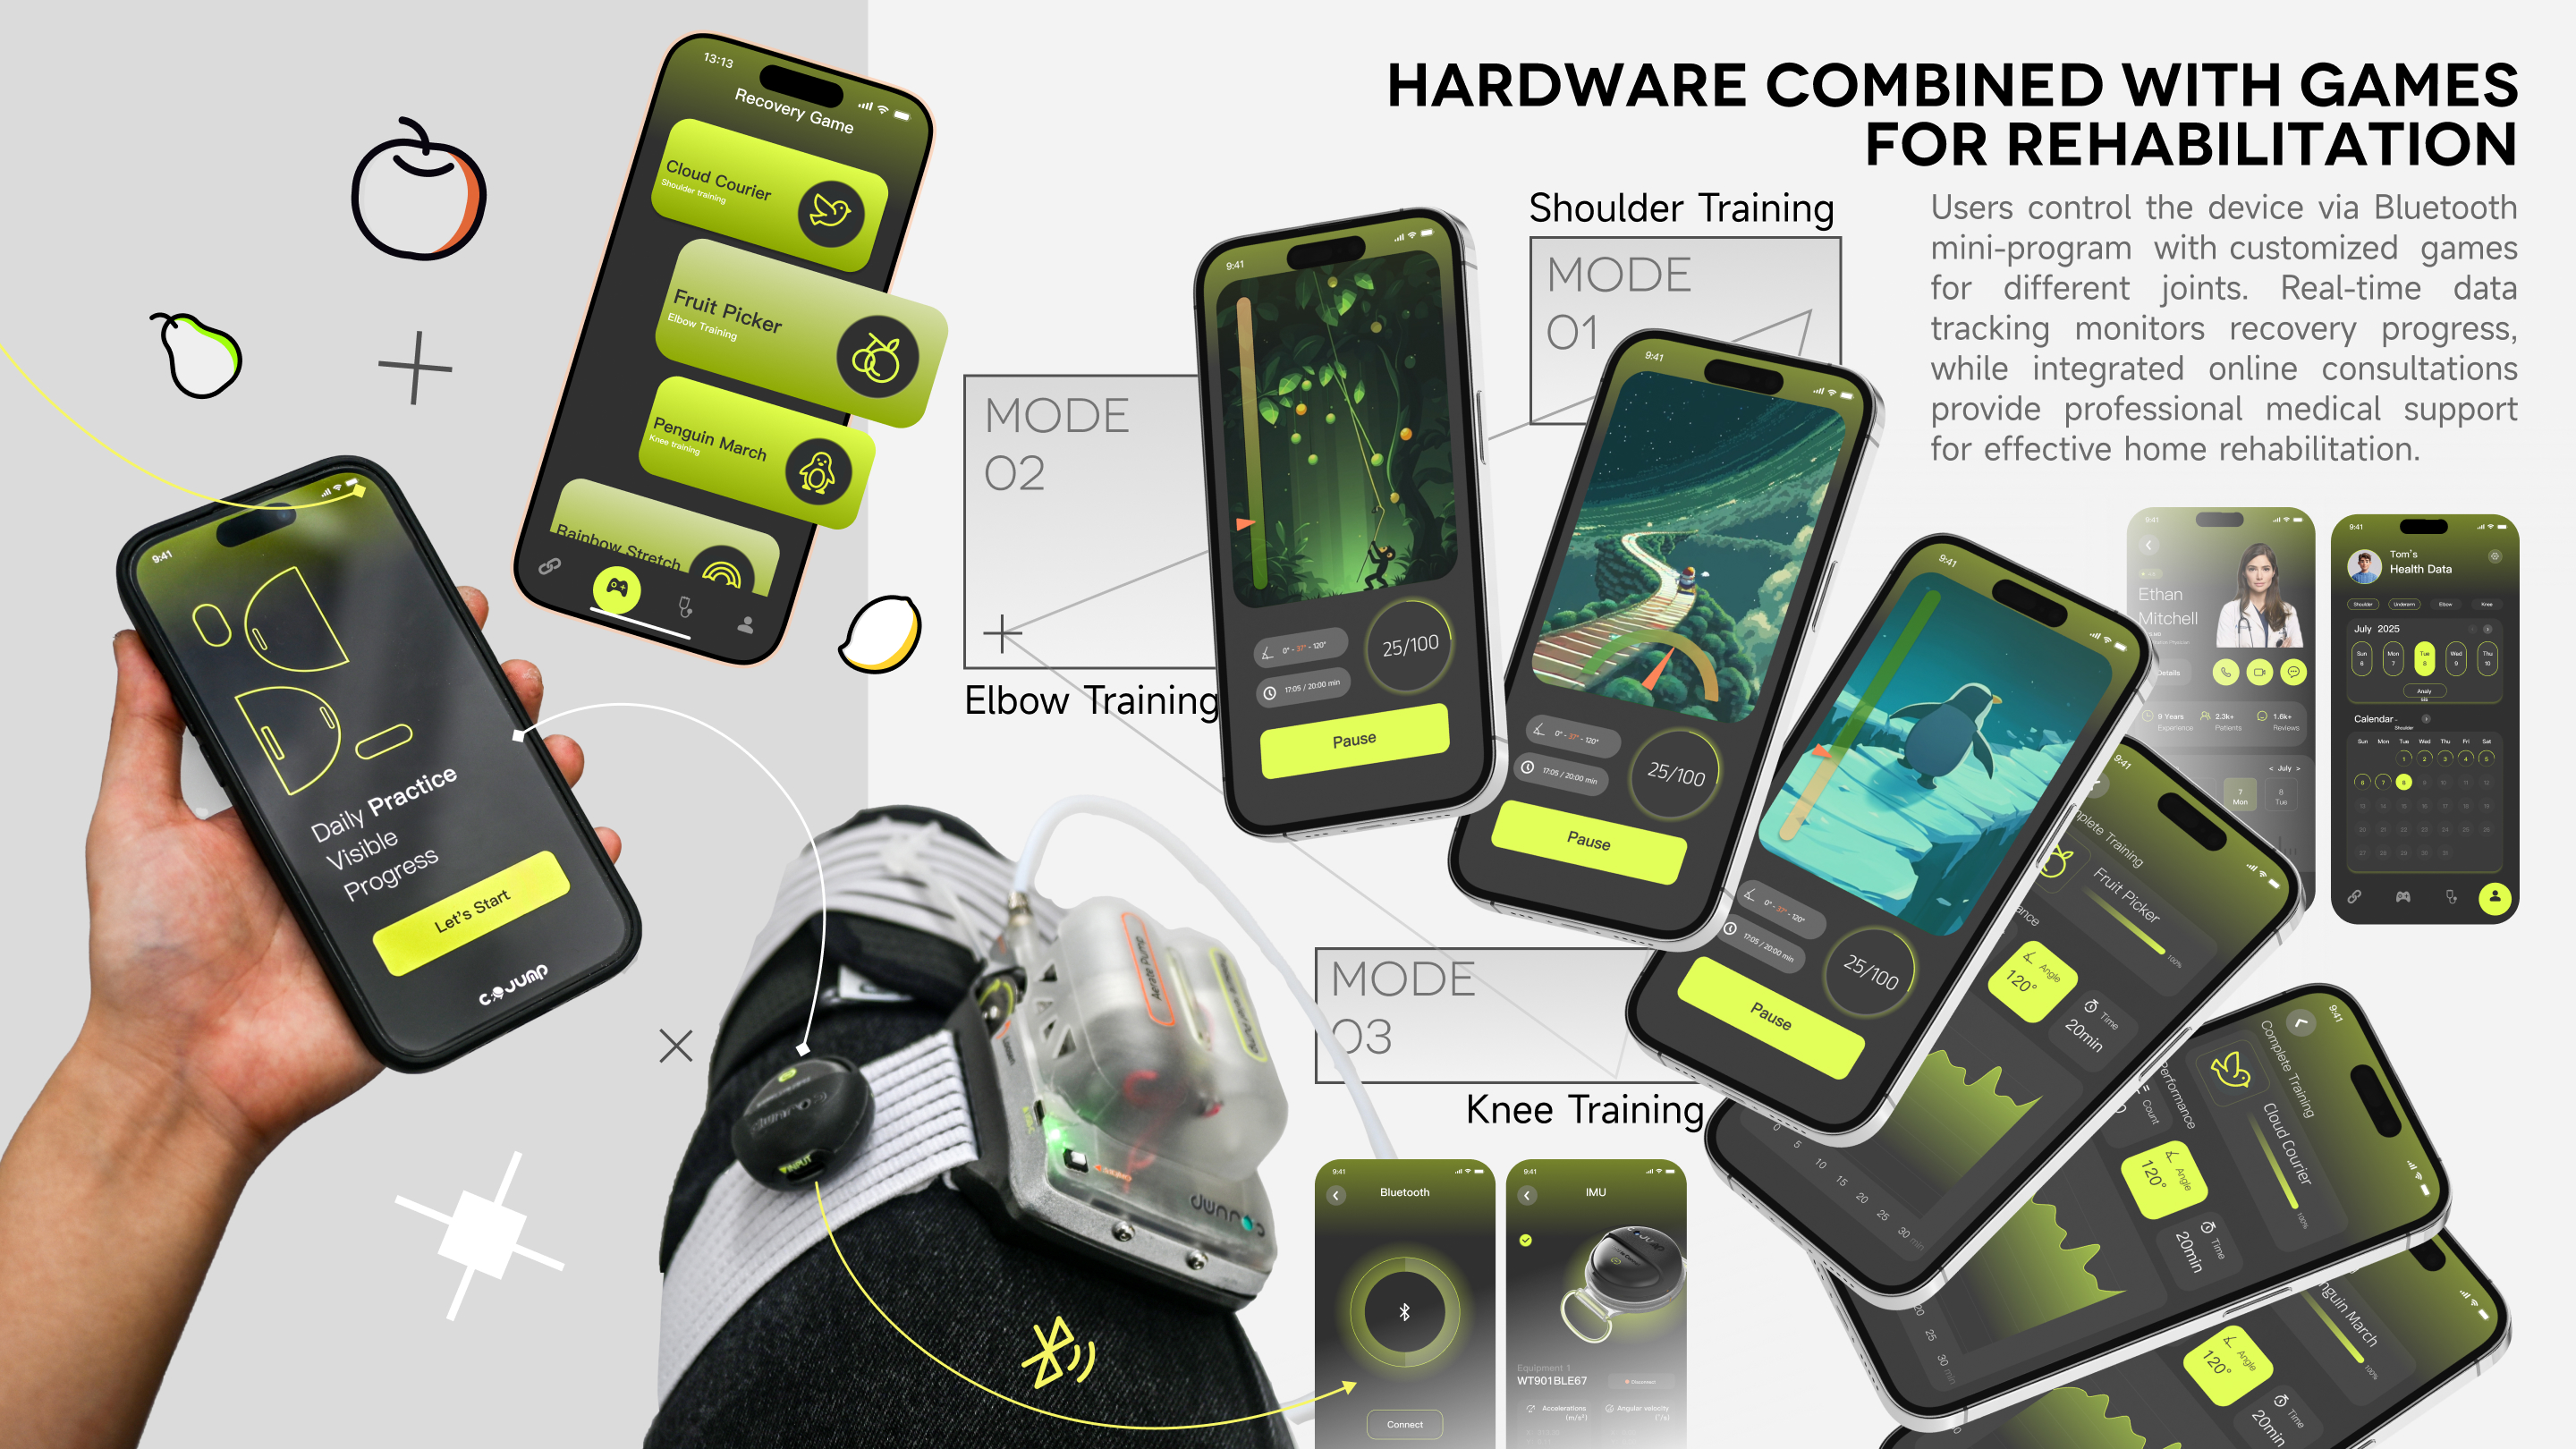
A modular, wearable joint rehabilitation robot that is safer, more portable, ergonomic, and clinically compliant. It integrates multi-joint adaptation, active/passive training, game rehabilitation, and health management for data-driven, personalized recovery.
The inspiration for this product came from a life-changing injury I experienced in college. During a volleyball practice, I tore my ACL from improper landing, starting months of rehabilitation. This experience made me feel the pain of injury patients and deeply understand the flaws in existing rehab systems. During recovery, I faced three challenges: fragmented medical resources, expensive, complex CPM machines that were unsuitable for home use, and inadequate home devices that lacked biomechanical accuracy and posed safety risks. These personal experiences led me to develop this revolutionary wearable rehab device using soft robotics.
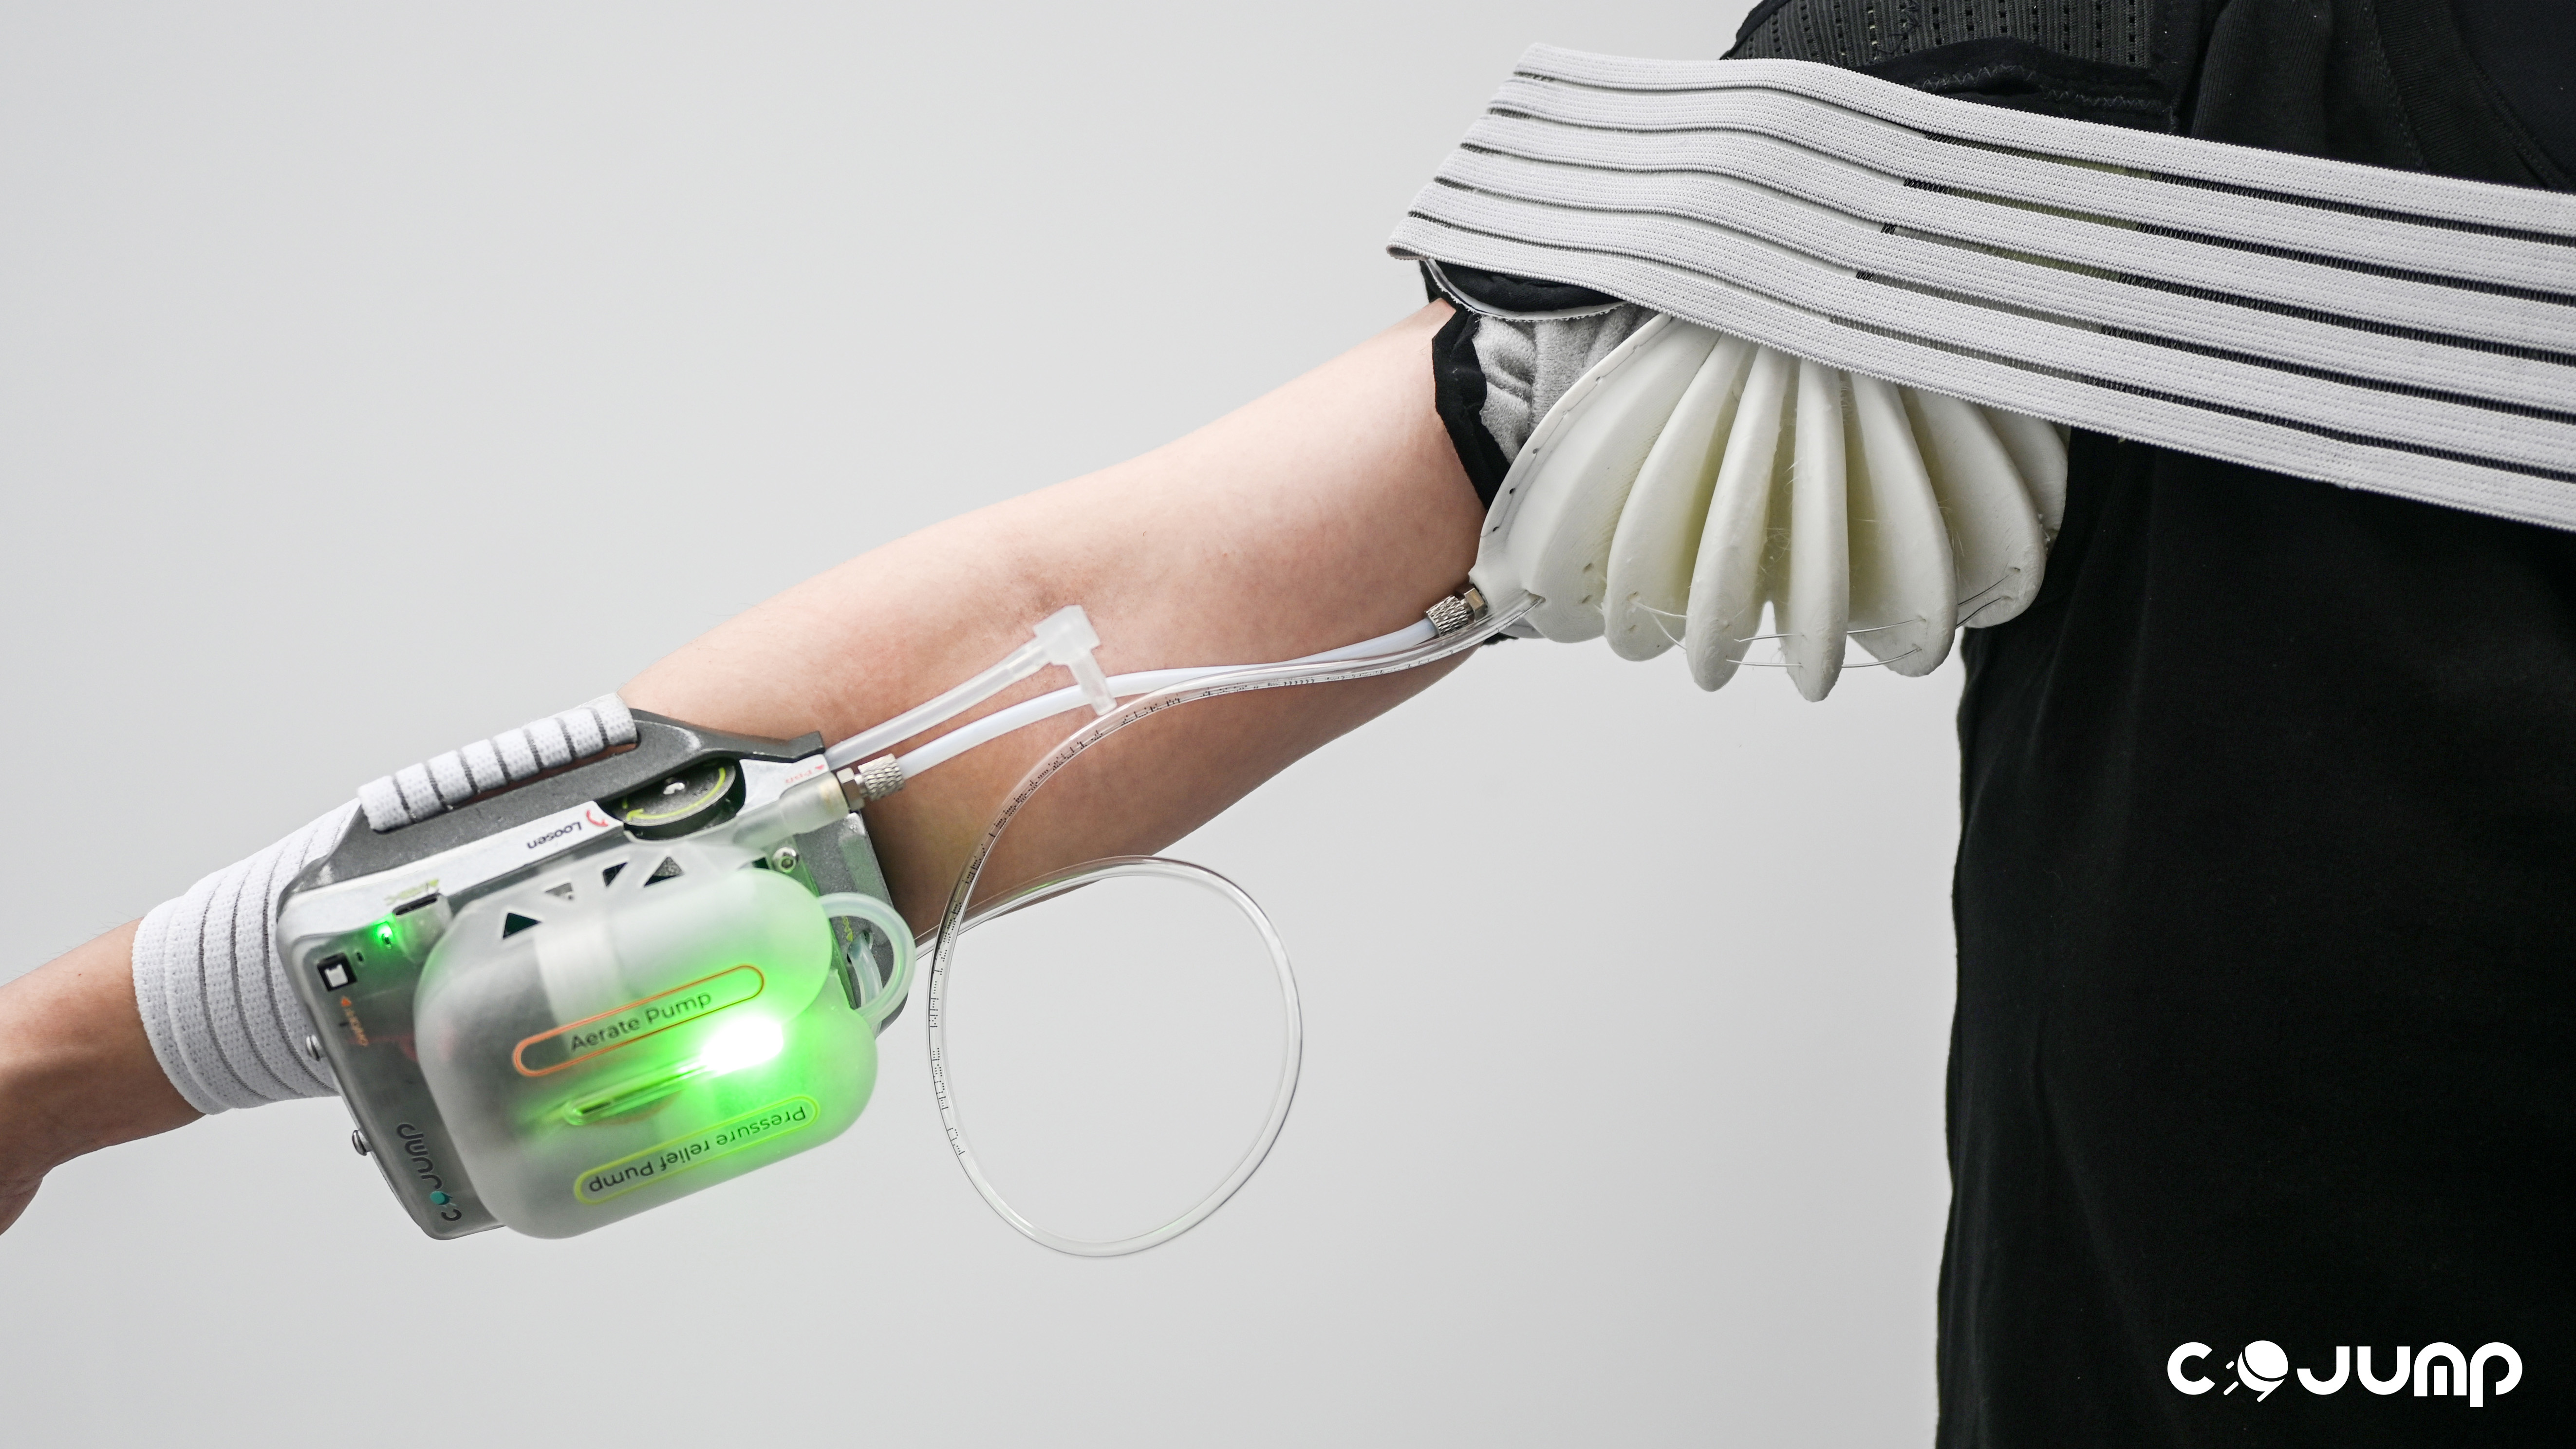
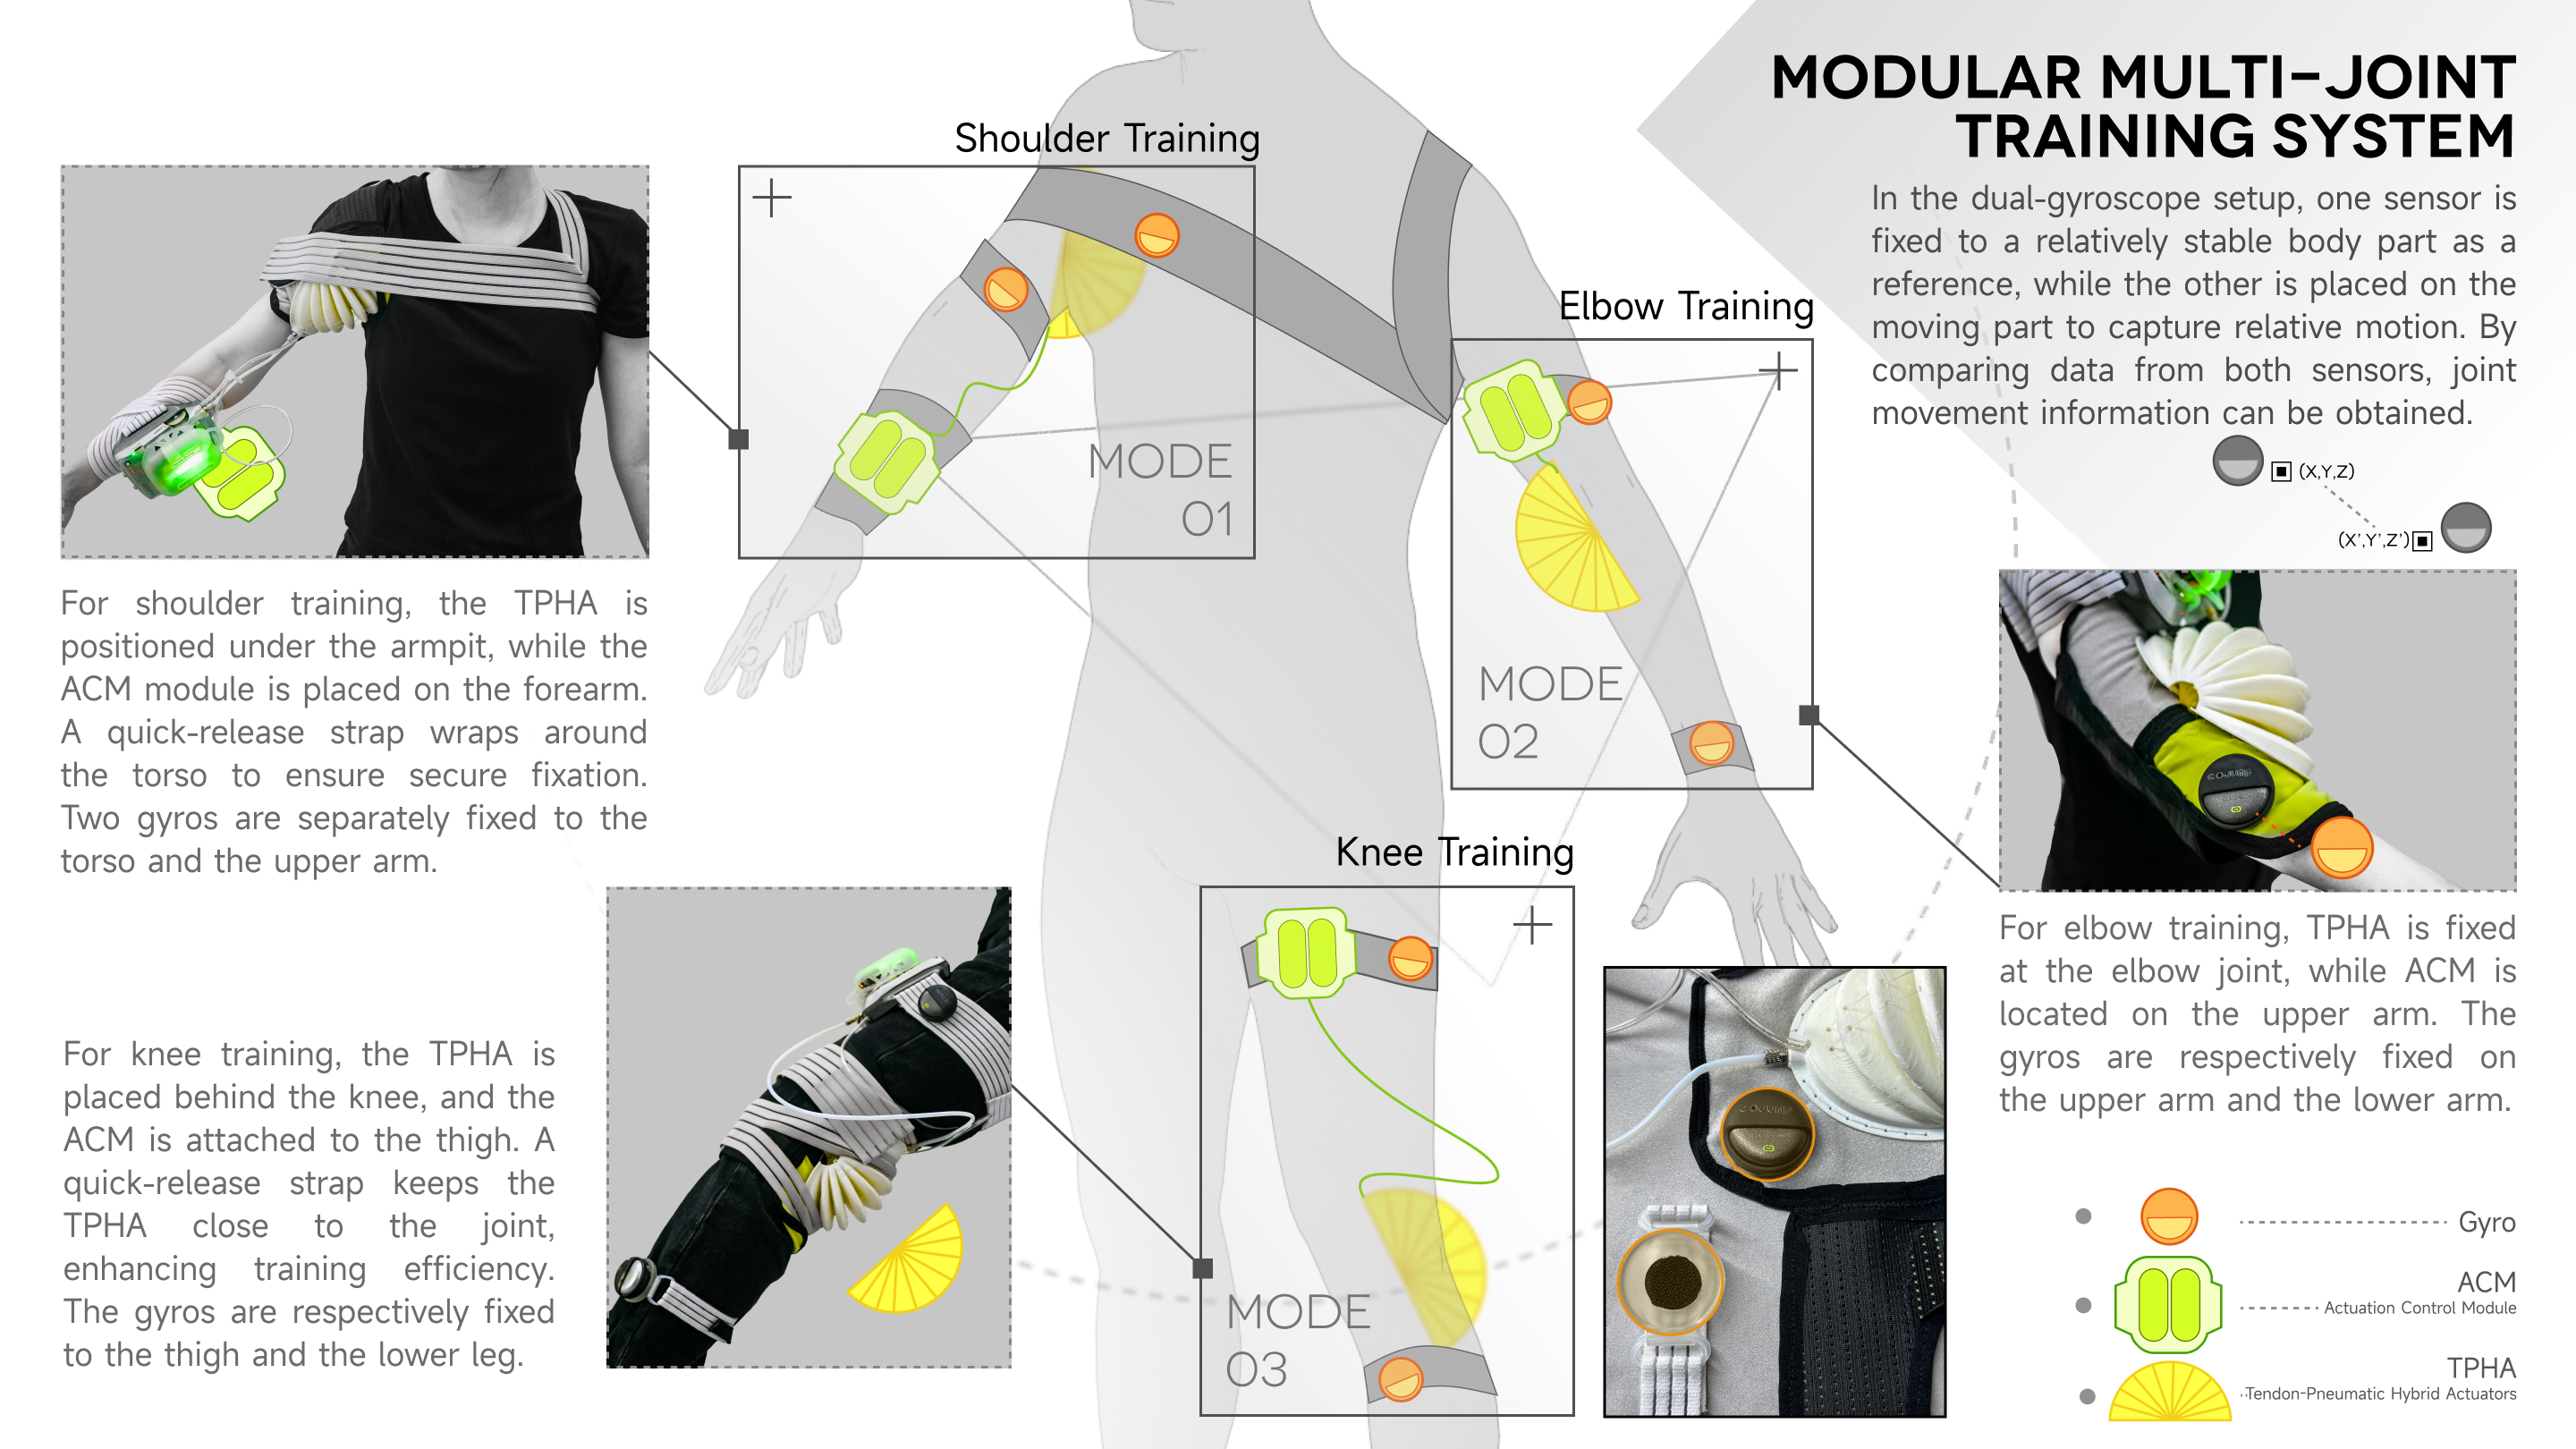
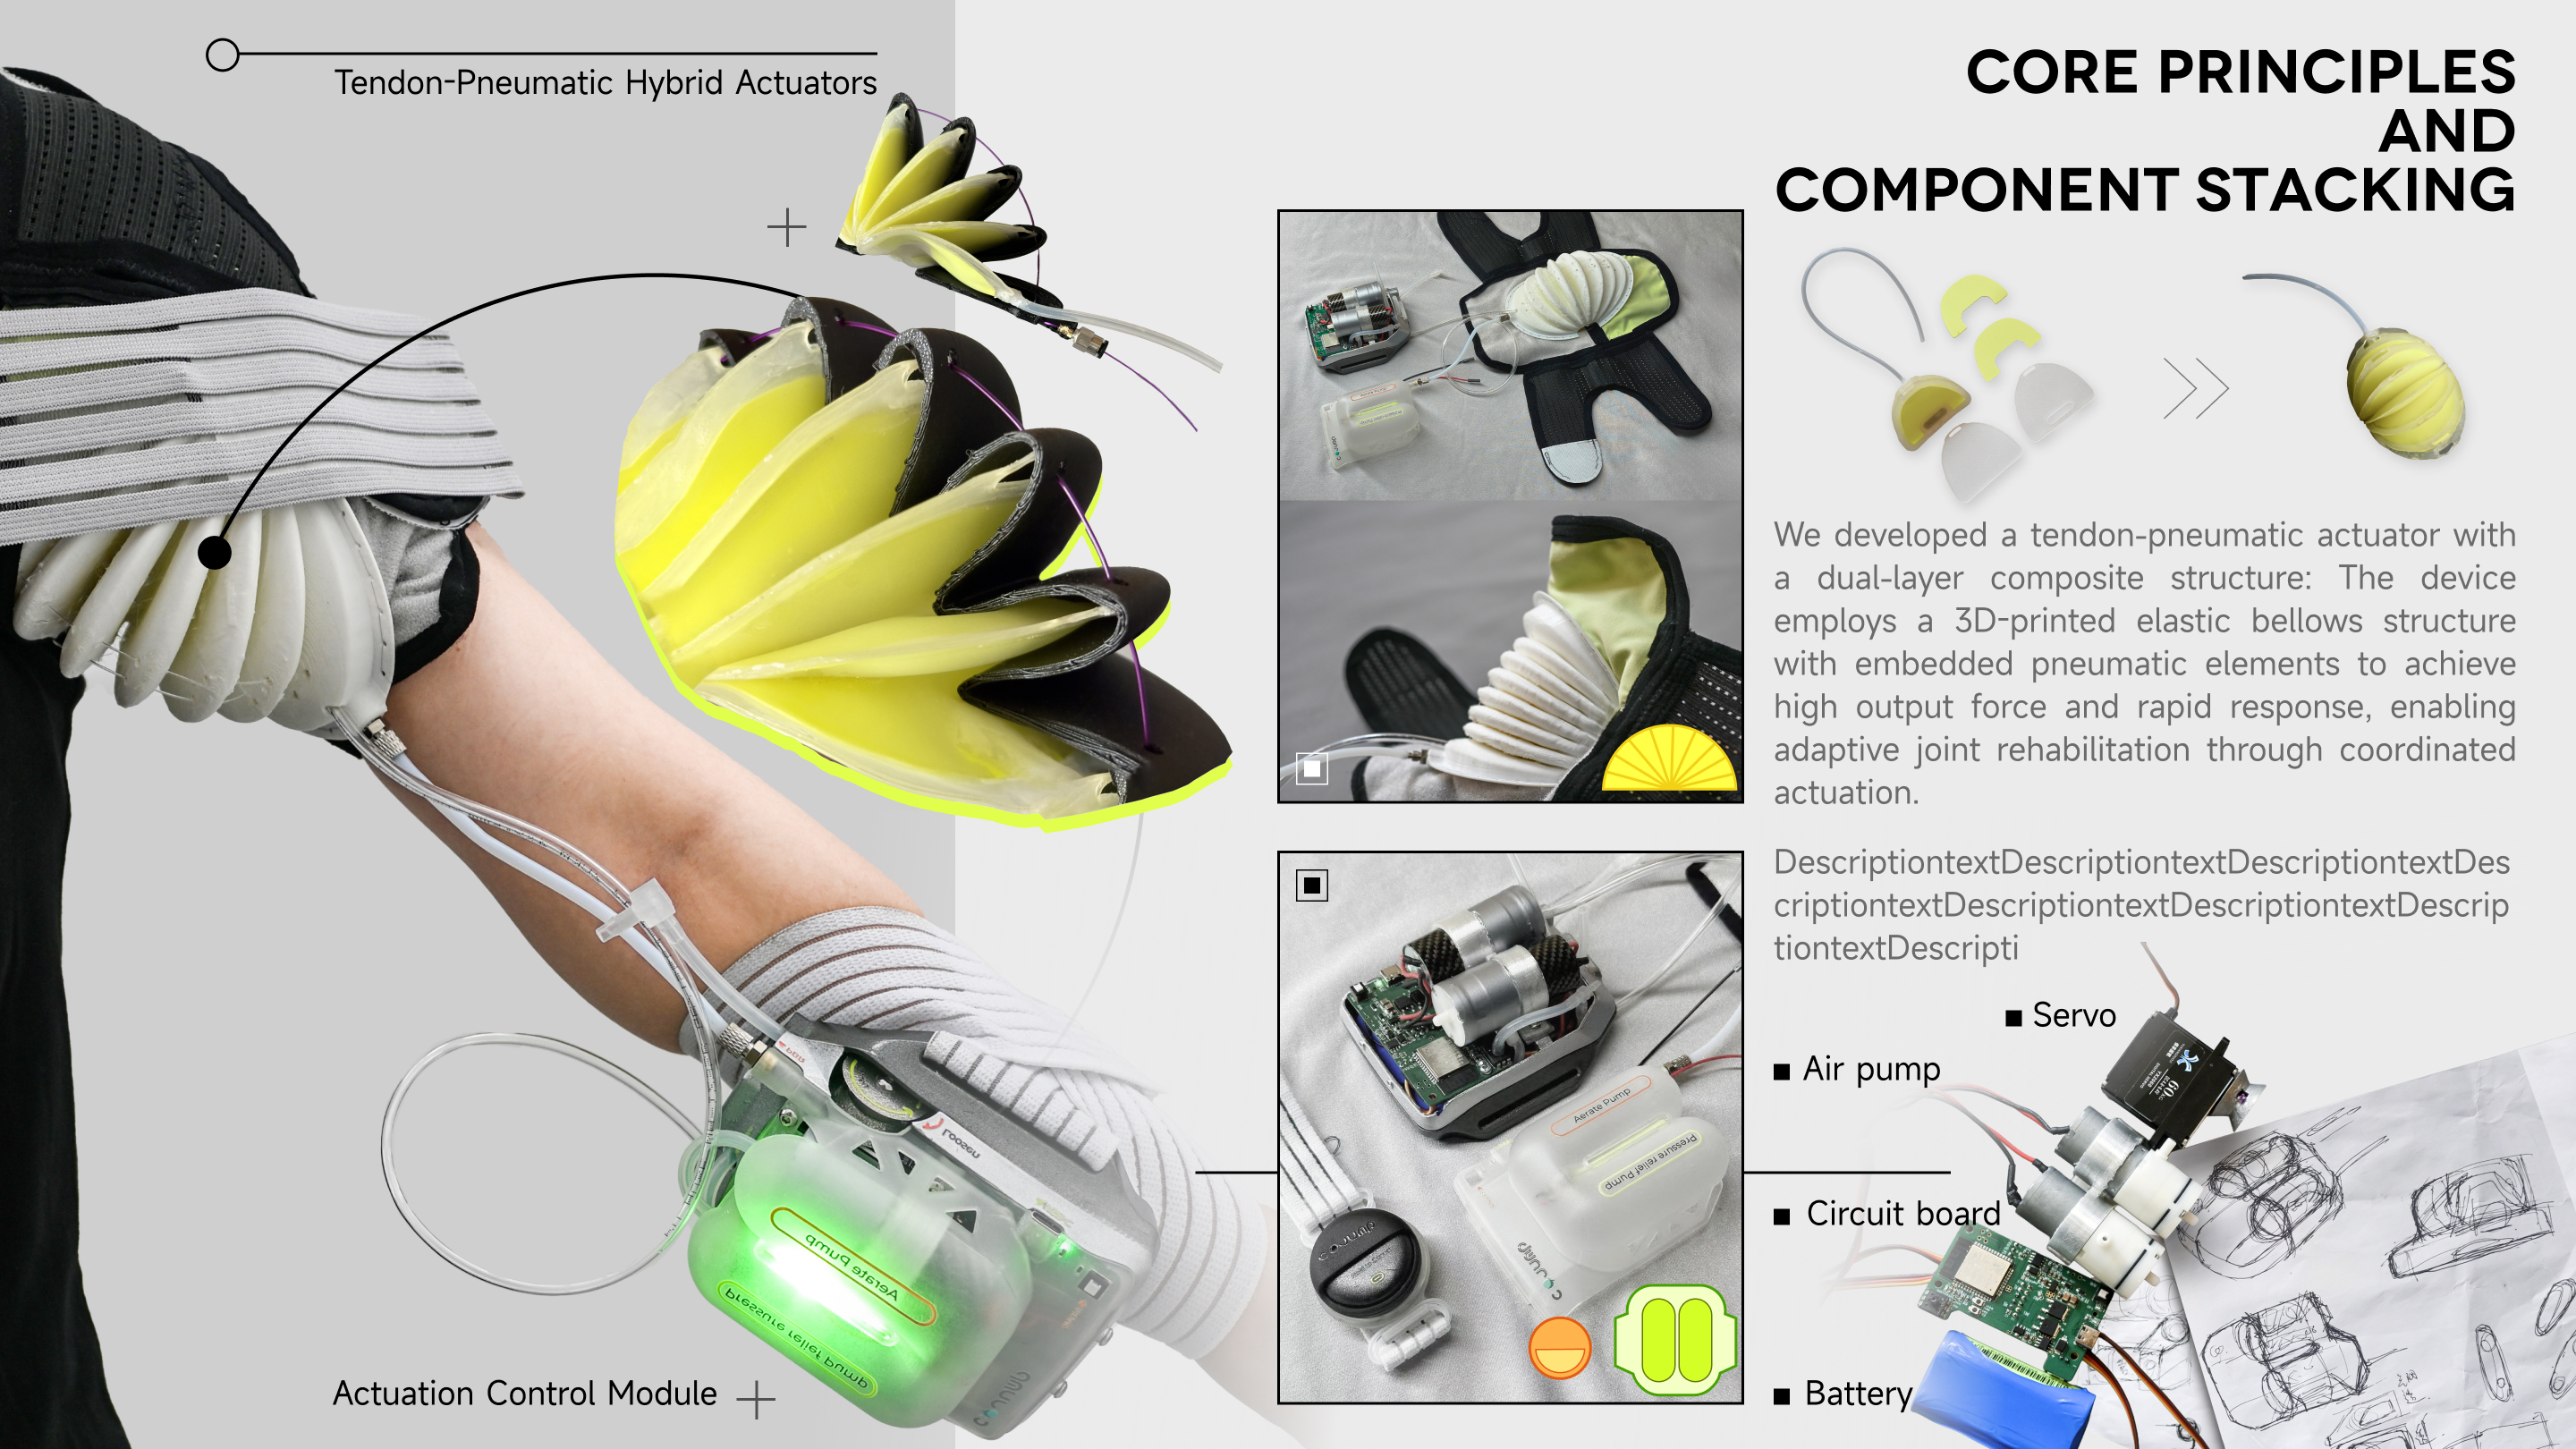
Our device safely and effectively aids joint rehabilitation with the following features: Dual-Drive Soft Actuator (Core Motion Unit): A flexible structure combining two drives: ·Pneumatic Drive: Adjusts air pressure for gentle, adjustable support, reducing impact, ideal for early rehab. ·Tendon Drive: Uses high-strength cables for precise movement control along a standardized path. Synergistic Advantage: Combines precise control (tendon) with adaptive support (pneumatic), fitting various body types. Modular Design: Specialized modules for joints like shoulders, elbows, and knees, with quick-release straps. It allows natural movement without restriction. Motion Monitoring & Control: Dual sensors track joint movement, adjusting the device for safe, personalized training. Rehabilitation Value: Simulates natural motion, reduces injury risk, supports multiple scenarios, and boosts patient engagement and recovery.
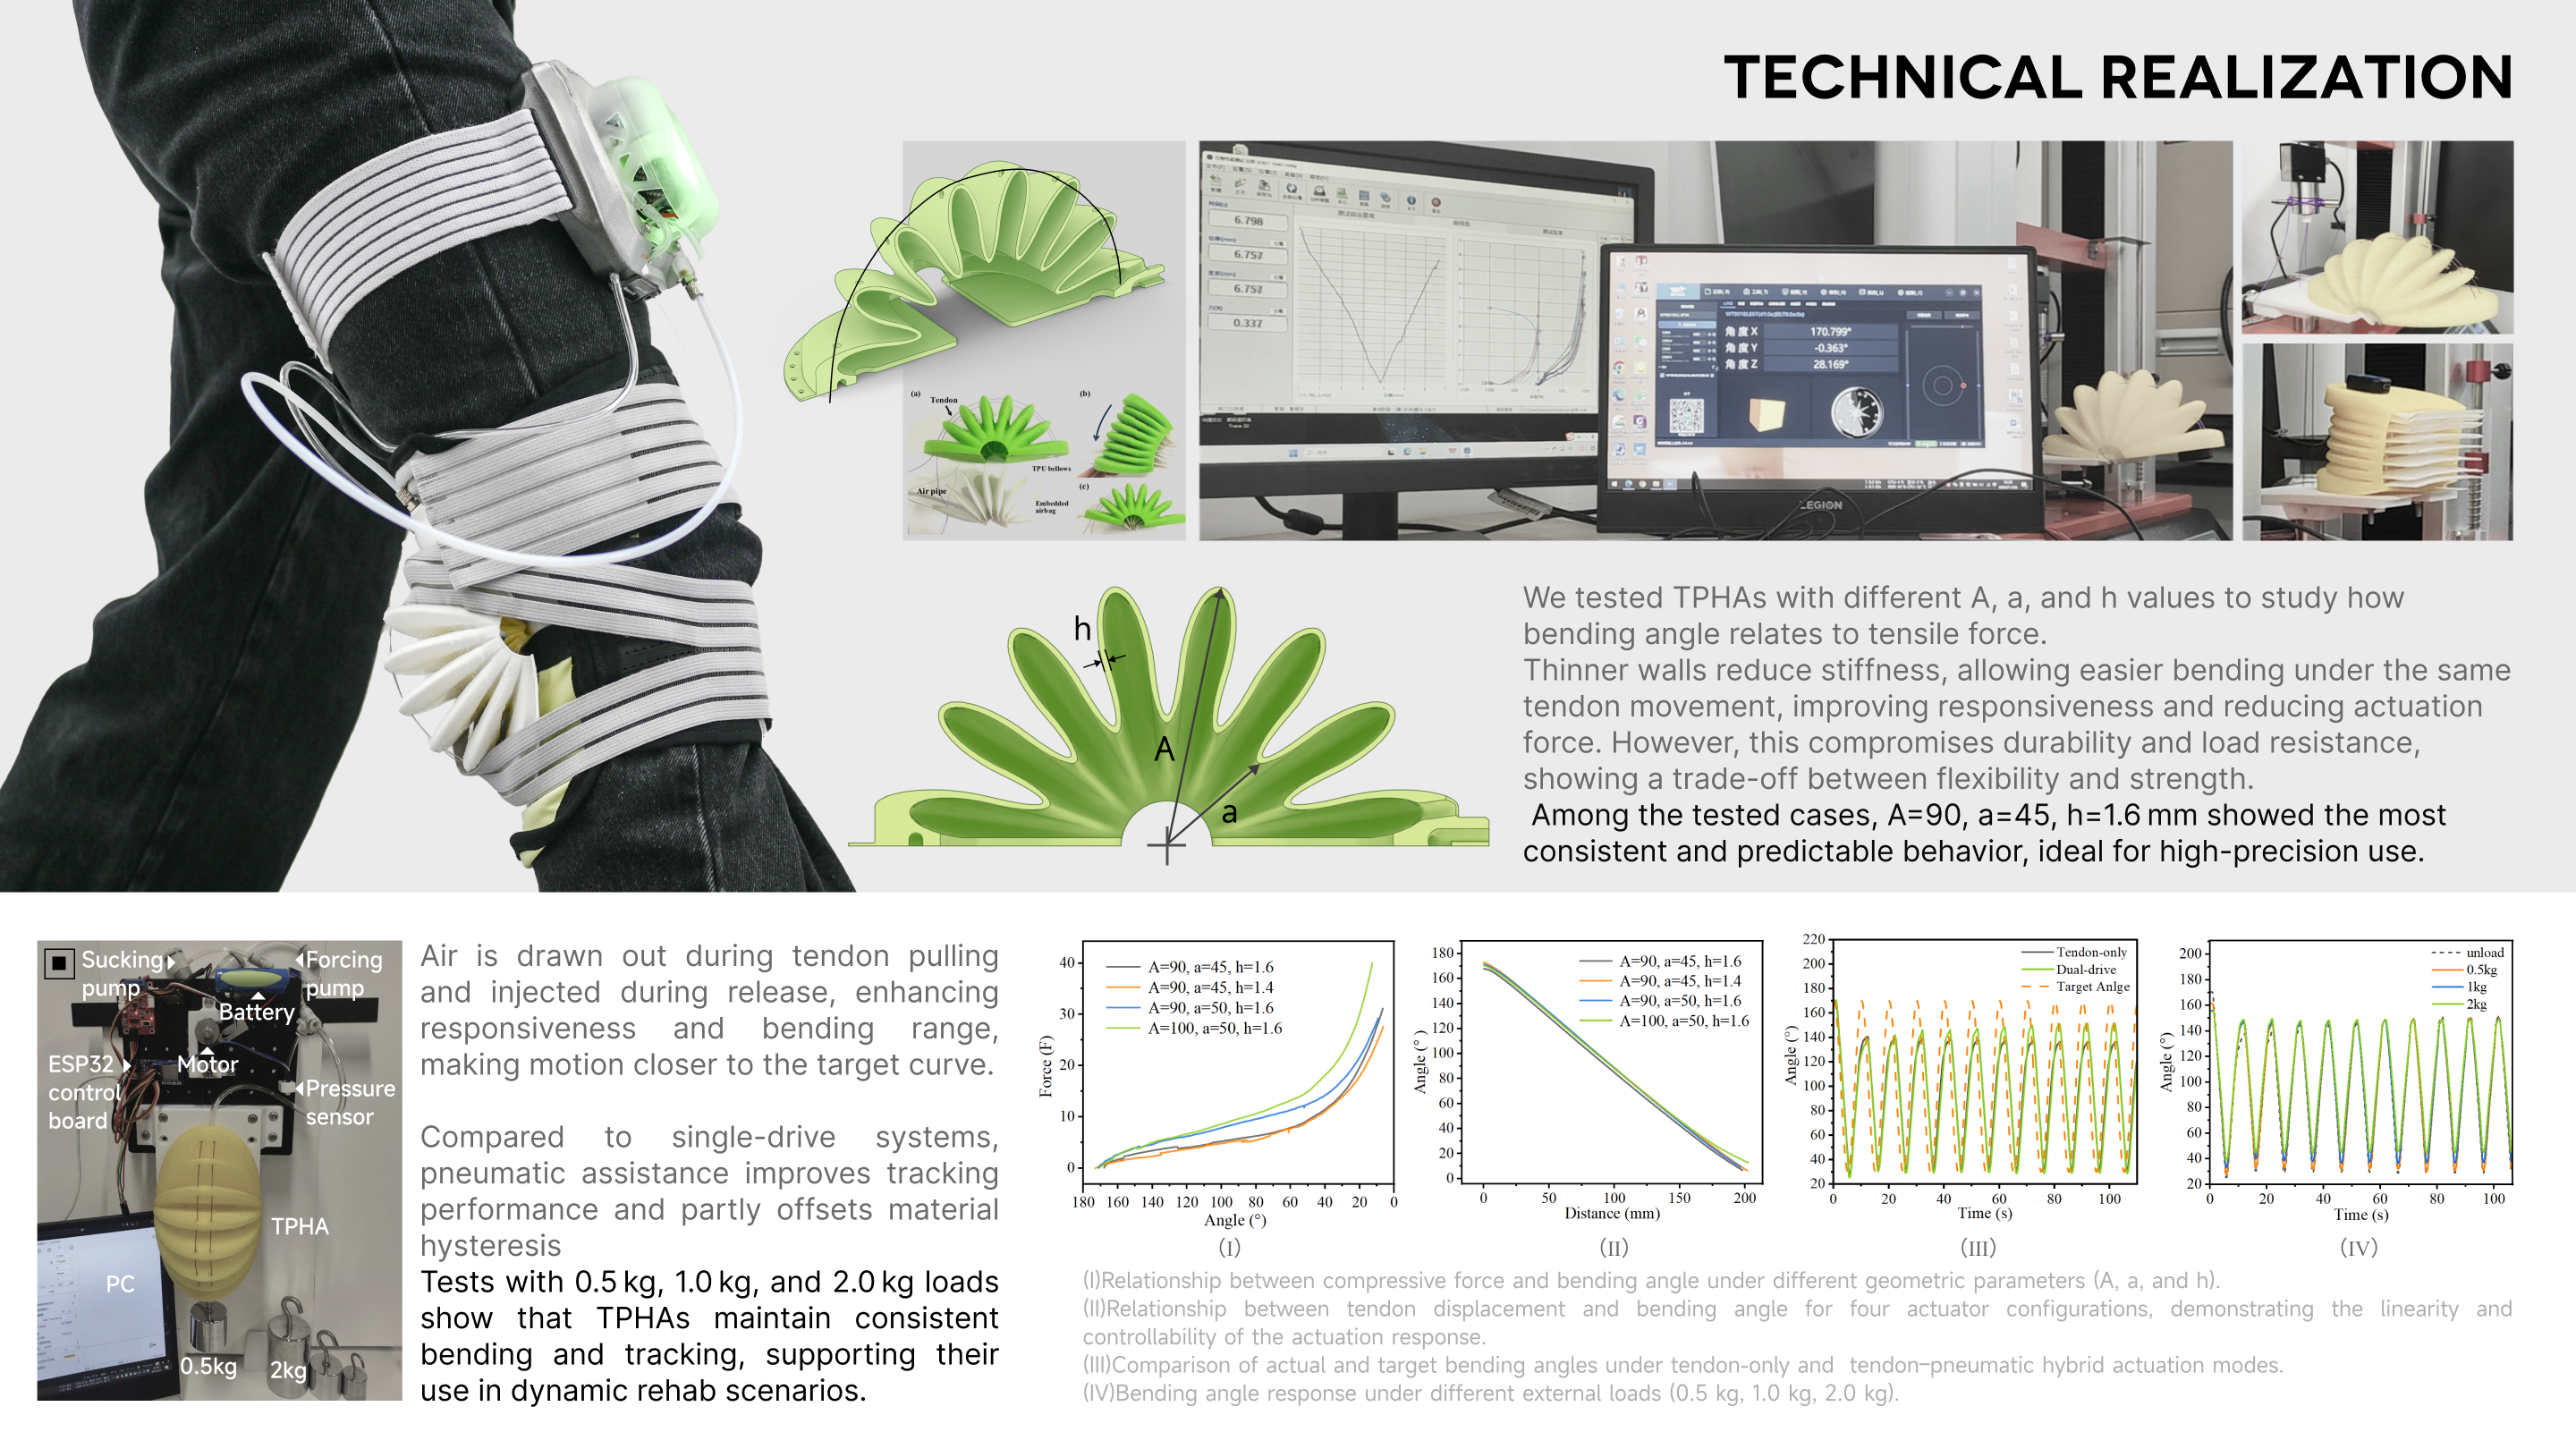
Our joint rehabilitation robot was born from my personal experience with knee rehab. The bulky CPM machines, frequent hospital visits, and financial burden inspired me to act. Over 528 million people globally suffer from osteoarthritis, with over 140 million in China. Conversations with doctors and patients revealed three core issues: 1) Safety risks (secondary injuries at home), 2) Biomechanical adaptation (rigid devices), and 3) Lack of portability (bulky equipment). This led to our goal: create a clinically safe, ergonomic, portable device for precise home rehab. Initially, we used flexible materials to simulate tendons. A 3D-printed TPU actuator with high-strength cables bent the joint. Early tests showed it lacked sufficient support. We then added a sealed airbag, leading to our core innovation: Tendon-Pneumatic Hybrid Drive (TPHA). This combines tendon control with soft, adjustable pneumatic support, balancing force, safety, and flexibility. We iterated on the design using paper models for comfort and usability. The compact control unit integrates core components and provides real-time feedback. Based on user feedback, we developed a safe, effective, portable, and user-friendly solution for home rehab.
Our design addresses key issues in joint rehab: portability, safety, control, and effectiveness. The tendon-pneumatic dual-drive actuator ensures precise control, force output, flexibility, and safety. With real-time data adjustments, modular design, and clinical-grade performance, we offer a revolutionary rehab experience. Tendon-Pneumatic Hybrid Drive (Core Tech): Combines tendon drive (precision cables) with pneumatic drive (adjustable air sacs) for balance between precision, comfort, and safety. Flexible Design for Safety: Flexible materials reduce impact and prevent secondary injuries. Modular design and quick-release straps support natural movement. Data-Driven Training: Adjusts intensity based on real-time data for optimal output. Modular, Portable Design: Adaptable components for different joints, compact control unit for home and mobile rehab. Cost-Effective, Clinical-Grade Rehab: Offers clinical-grade rehab at a fraction of the cost.
免责申明:本文中部分图文内容转载自jamesdysonaward,相关版权归原作者及出处所有。若涉及post plant侵权,请及时联系我们,我们将第一时间删除处理。